ROS
Robot Operating System a flexible framework for writing robot software, providing tools and libraries.
Projects
 10 Aug 2022
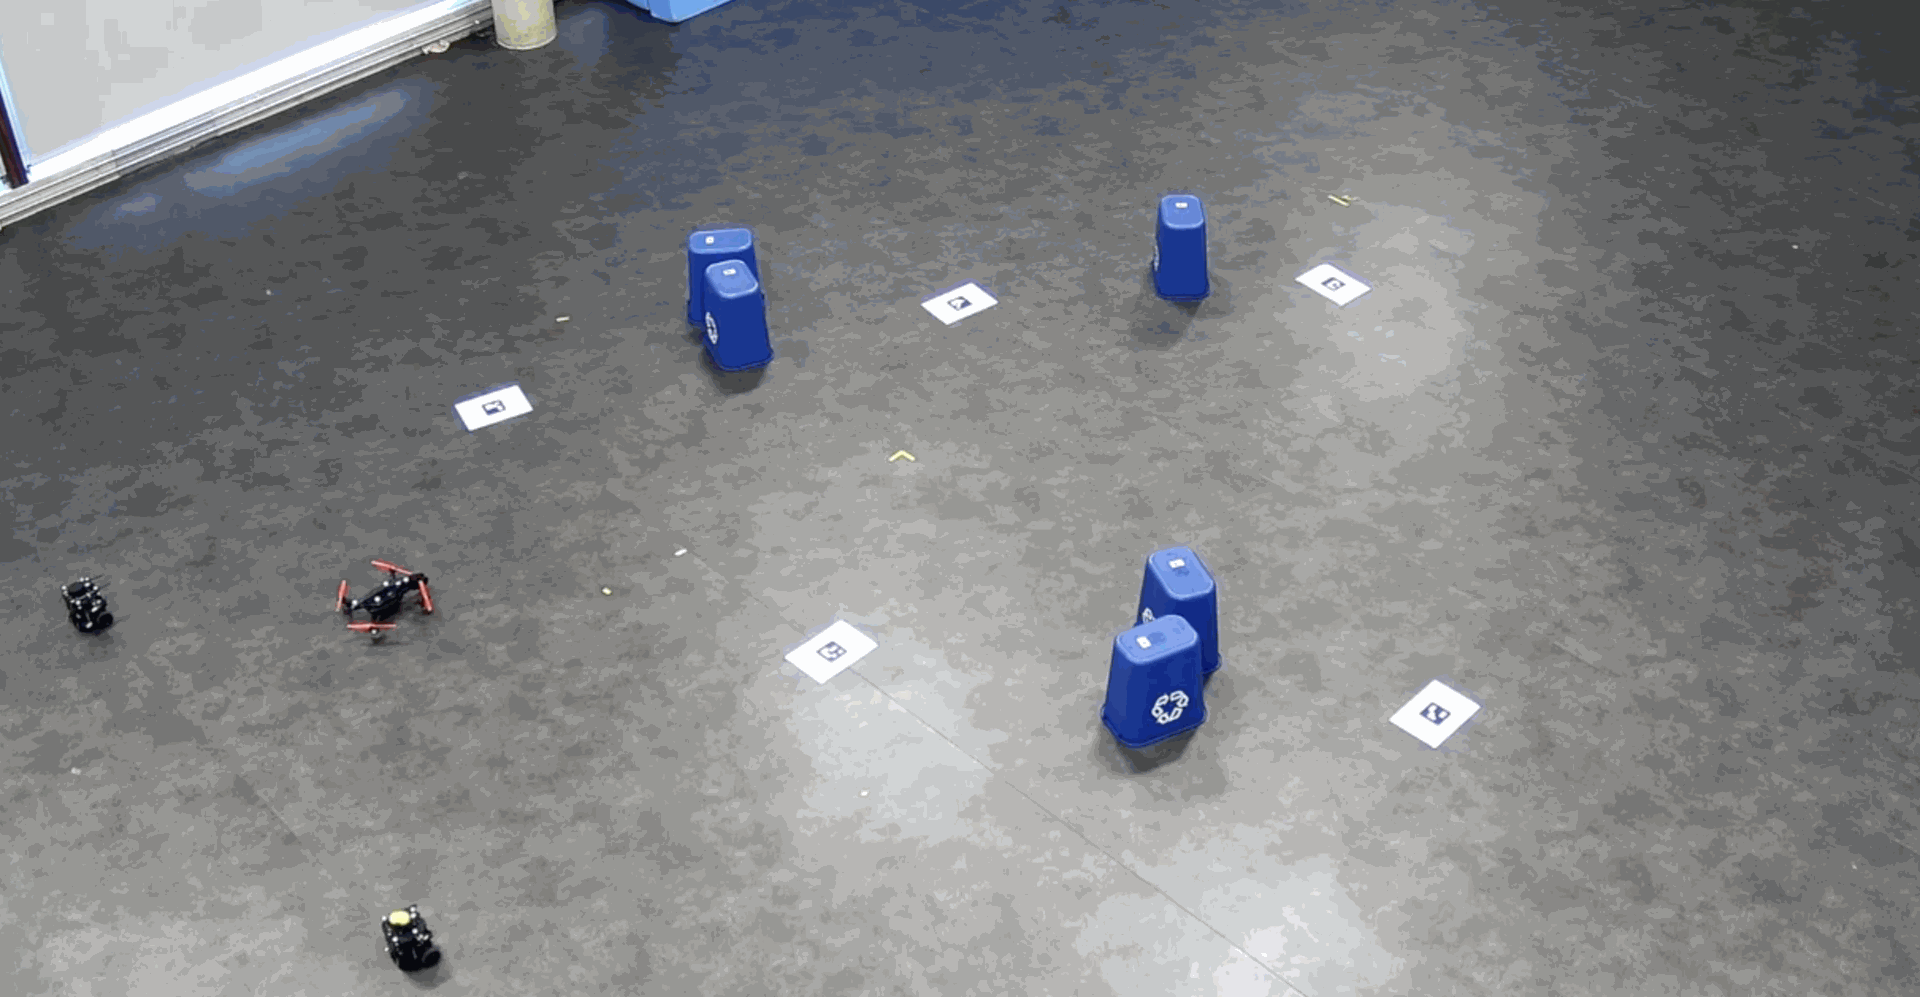
Multi-Robot ROS Architecture for UGV/UAV Coordination
Modular ROS architecture enabling coordinated task execution between drones and ground robots using TCP.
 10 Mar 2022
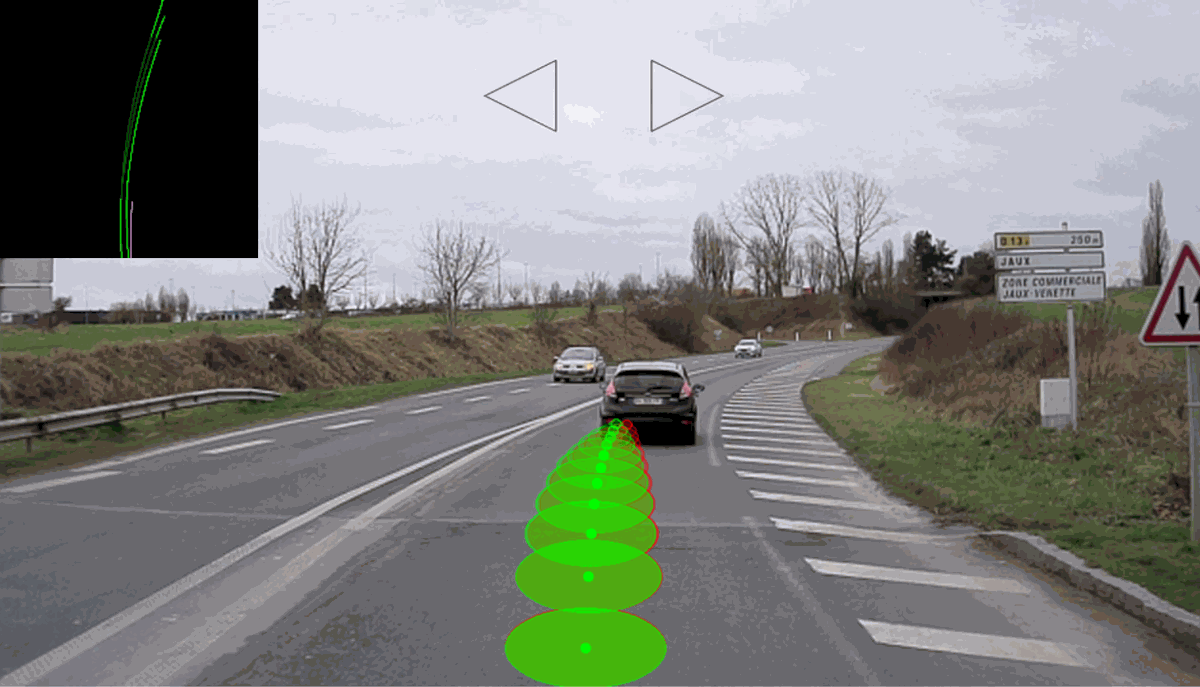
Human Driving Behavior Prediction
Prediction of short-term human driving behavior using previous vehicle states, based on a deep learning model integrating multiple sensors.
 10 Jan 2022
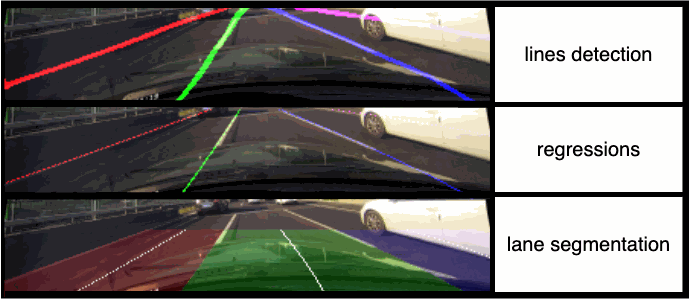
Lane Detection
Lane detection from camera images using a deep-learning autoencoder.
 10 Dec 2021
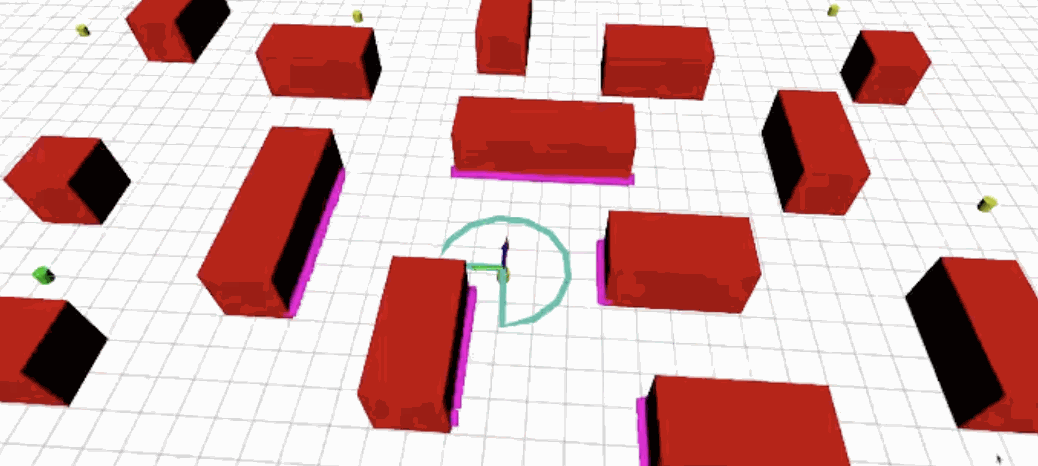
Optimization of the Dynamic Window Approach (DWA)
Gradient descent formulation applied to the Dynamic Window Approach for improved convergence and trajectory quality.
 10 Dec 2020
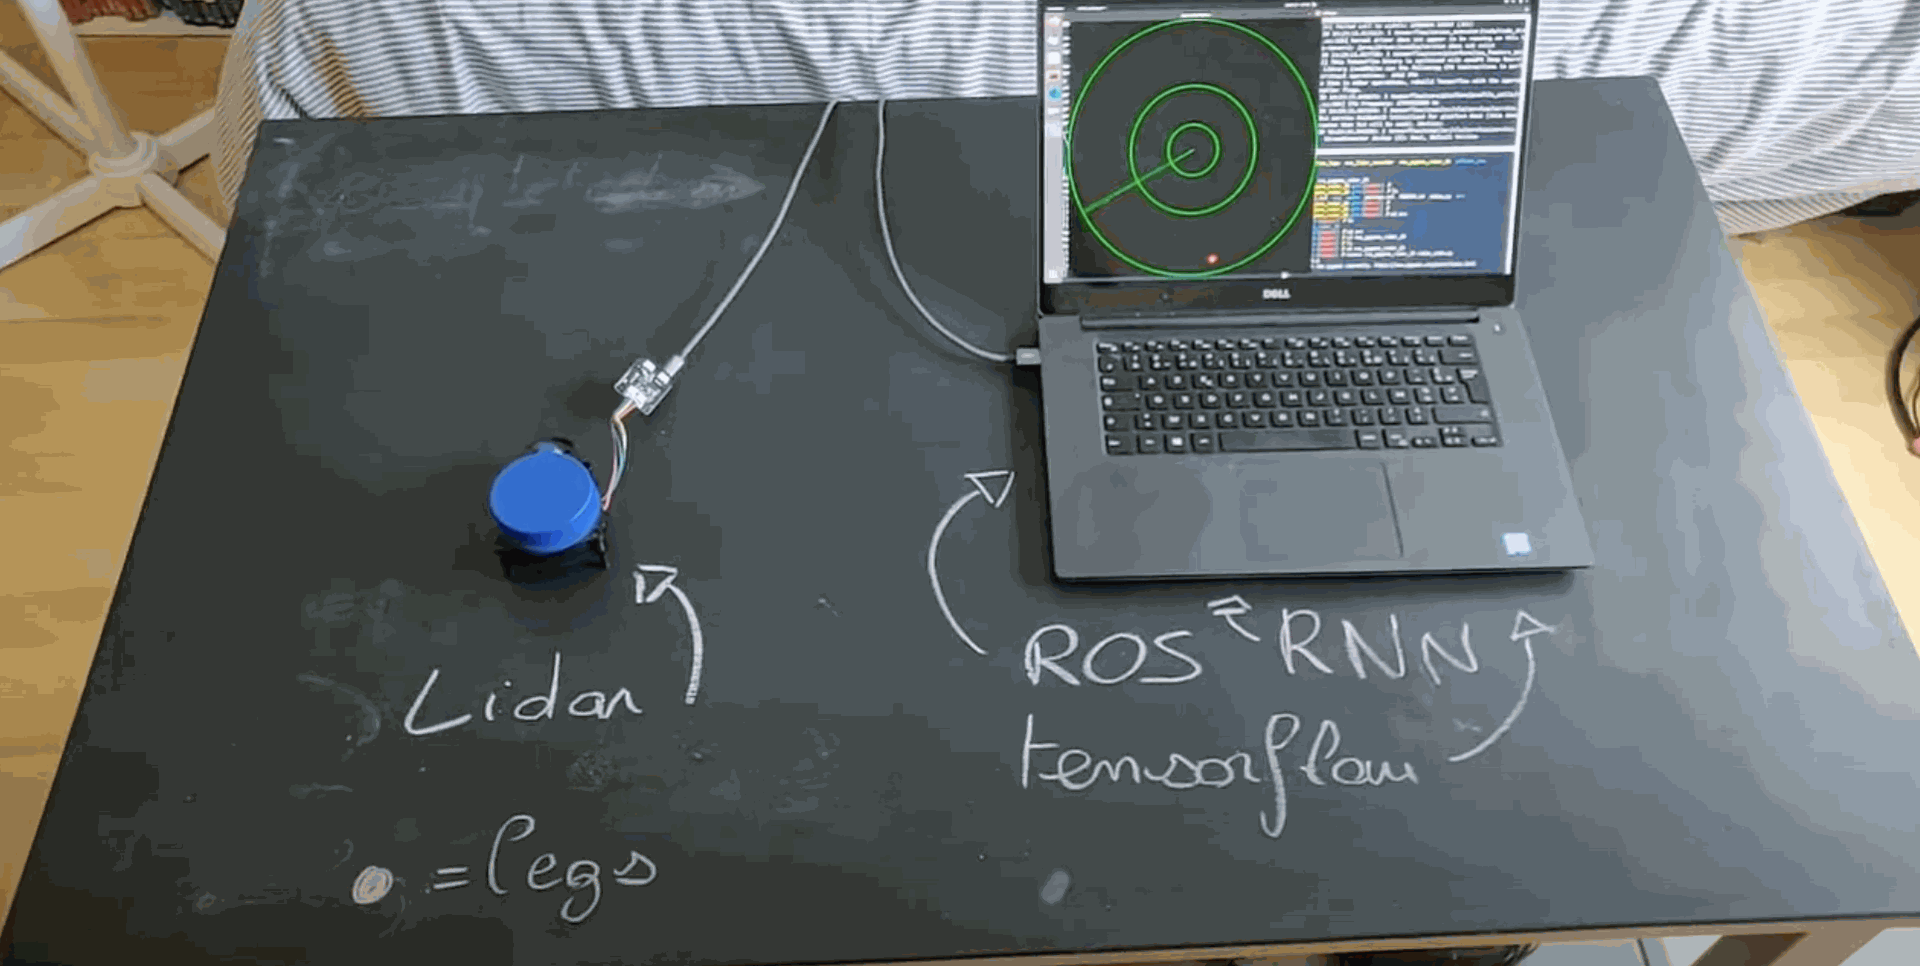
Leg Detection Using a 2D LiDAR
Leg detection using an LSTM classifier on spatial LiDAR sequences.
 15 Jun 2020
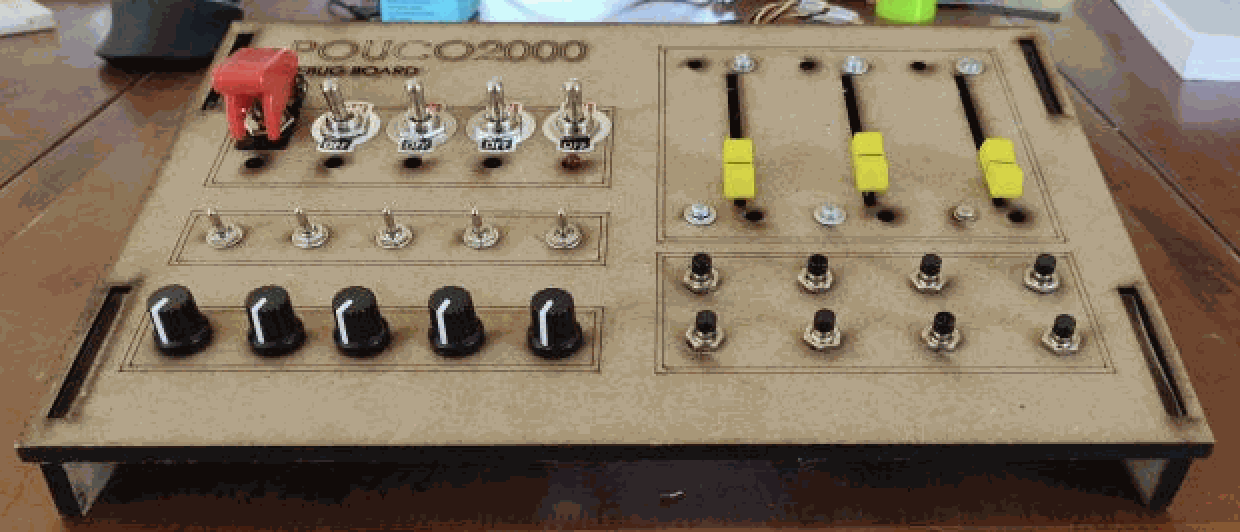
Pouco2000 - Customizable Physical Interface for ROS Robots
Modular physical control panel for interacting with ROS-based robots, with Arduino and ROS integration.
 01 Feb 2019
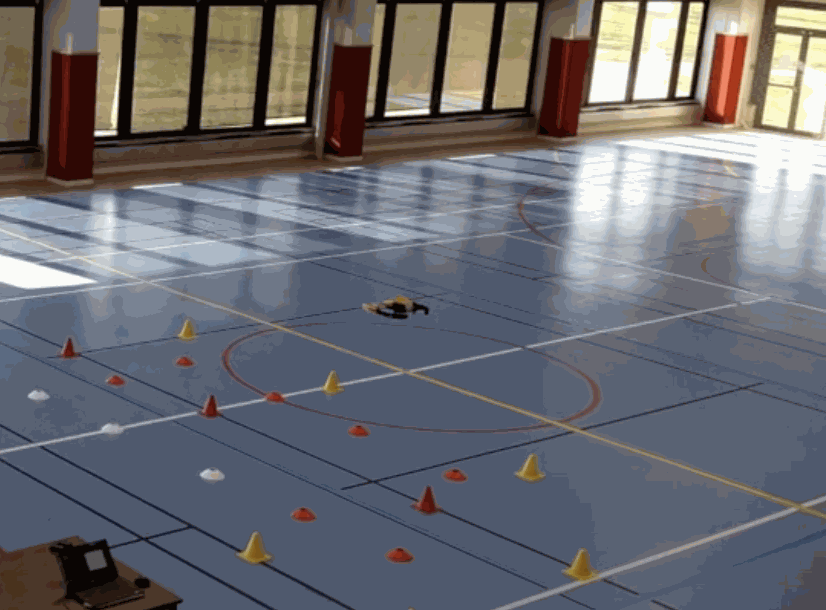
Drone Control with ROS
Control of a Parrot drone using ROS.
Publications
Prediction of human driving behavior using deep learning: a recurrent learning structure
2022 IEEE 25th International Conference on Intelligent Transportation Systems (ITSC)