Projects
20 projects, most recent first.
2025
 10 Nov 2025
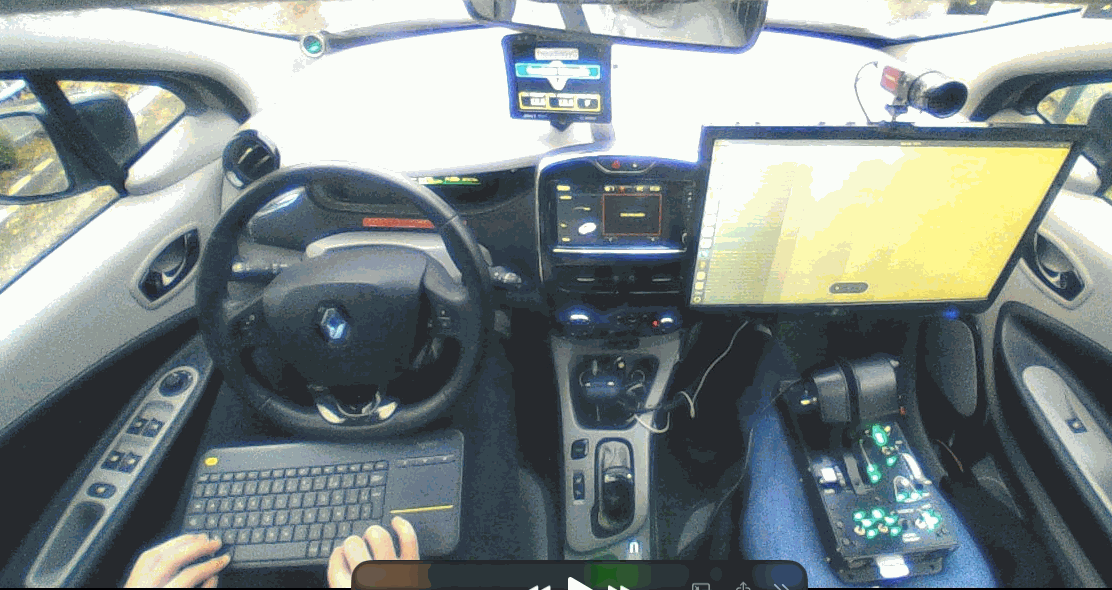
Autonomous Vehicle: Teleop
Longitudinal control by teleop.
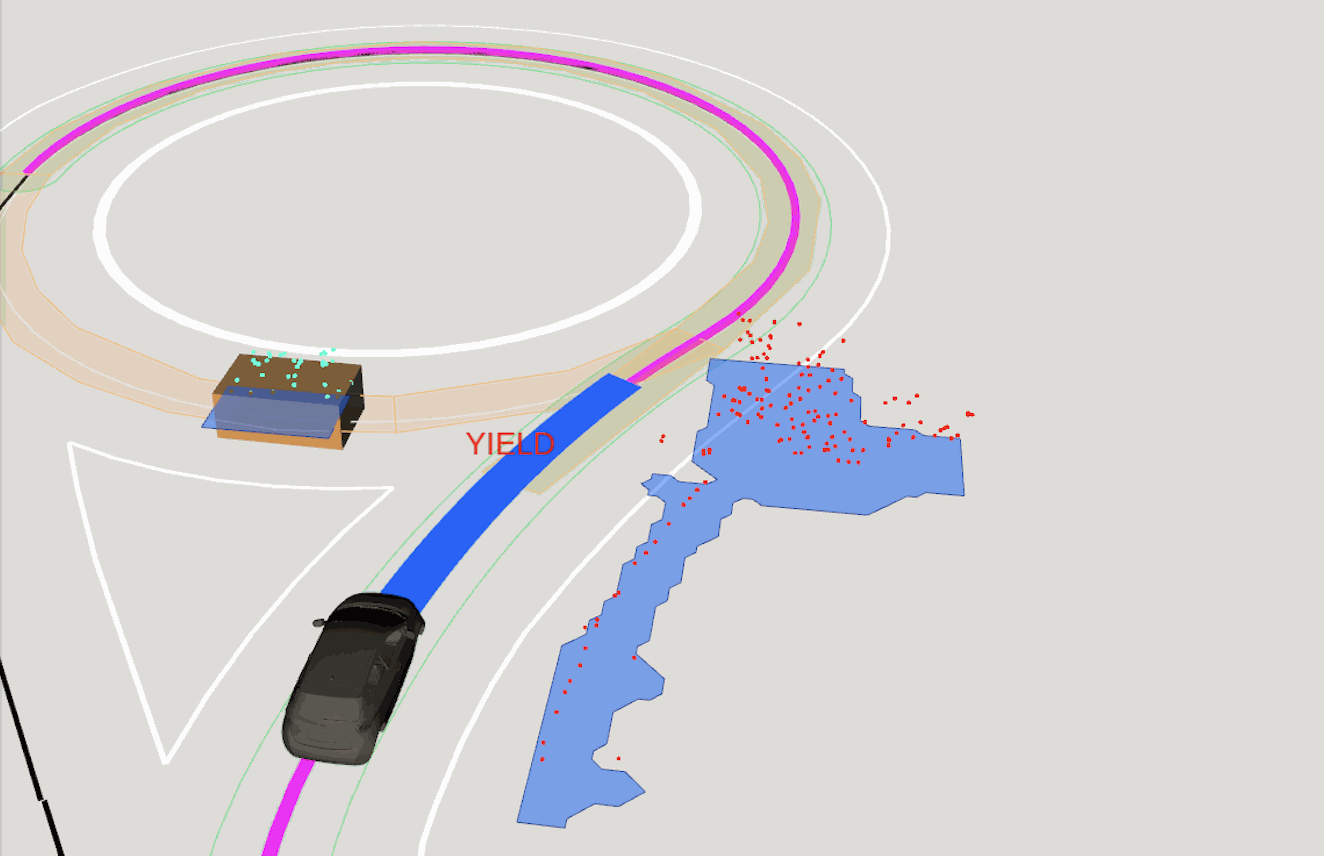 14 Oct 2025
LiDAR Detection & Decision Making
Modular LiDAR perception pipeline for autonomous driving, built with ROS2 and configurable geometric clustering.
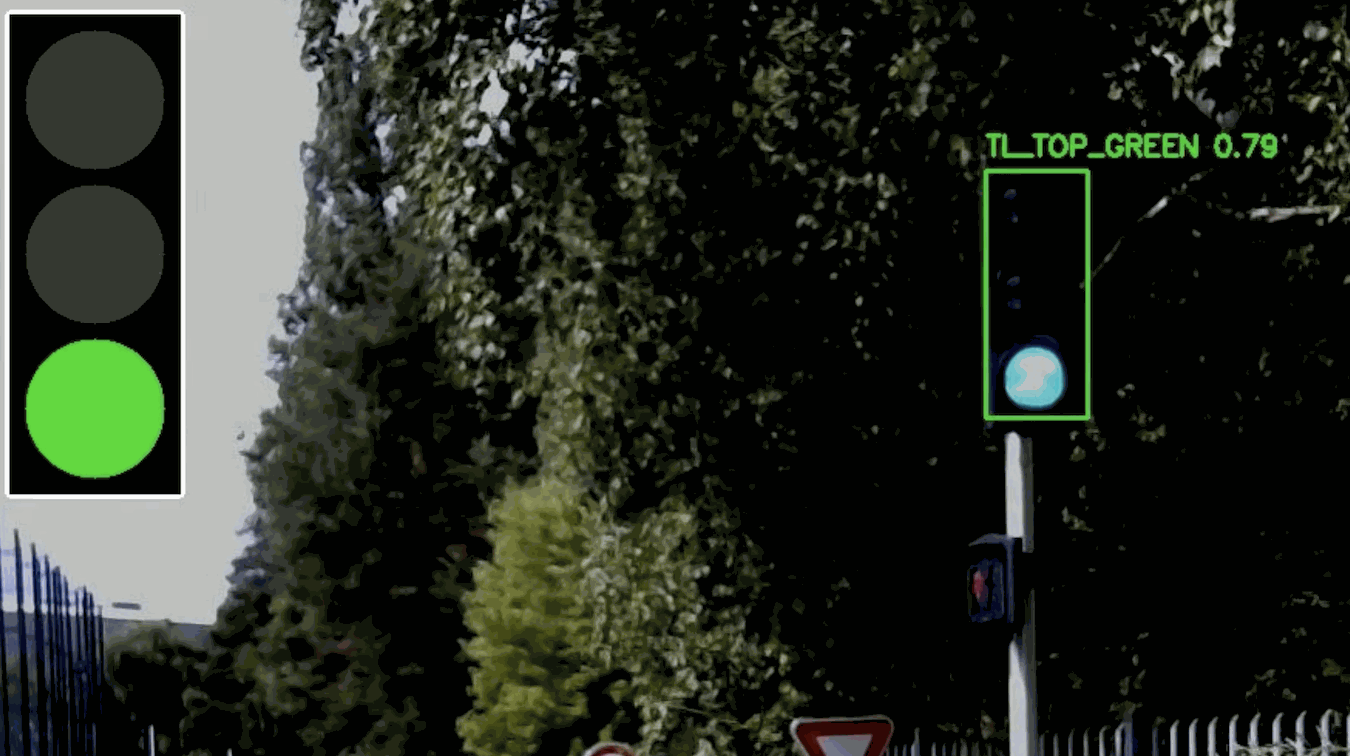 15 May 2025
Traffic Light Detection & Control
Detection of traffic lights, and adaptation of vehicle control depending on the light state.
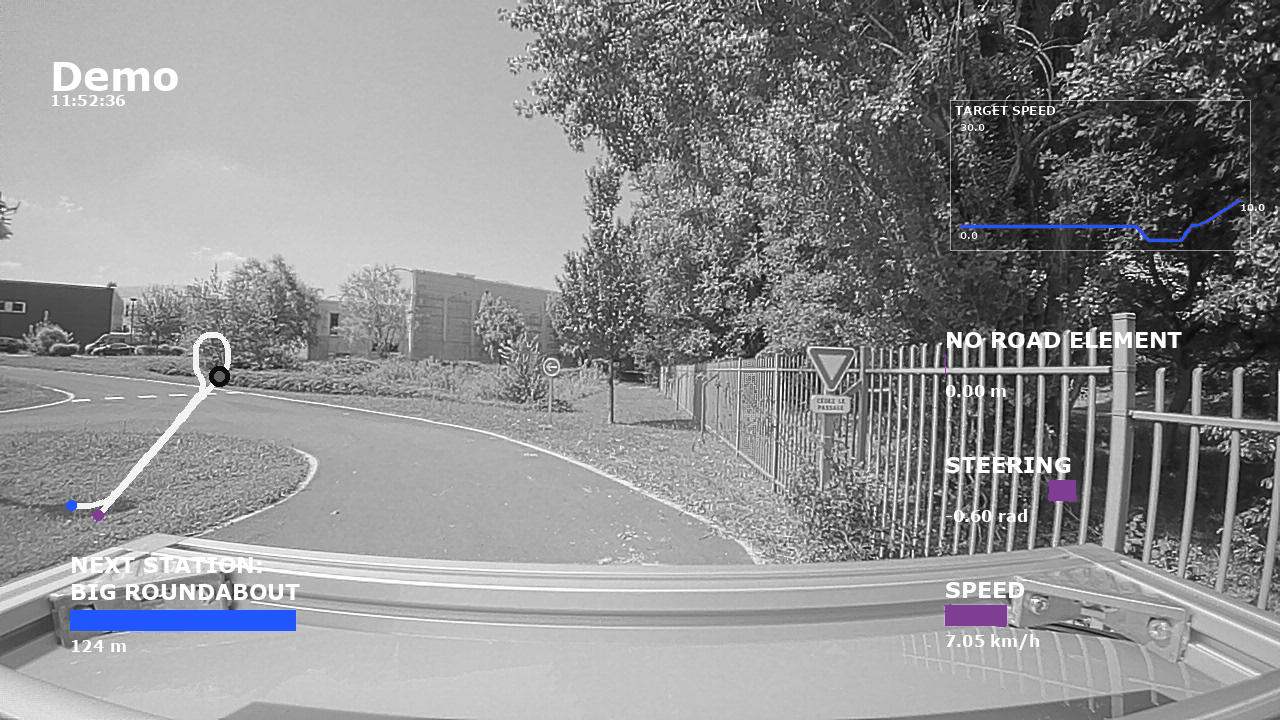 01 May 2025
ROS2 - Dashboard Framework
Configurable ROS 2 dashboard framework for visualizing data, controlling nodes, and exporting video-based UI layouts.
 01 May 2025
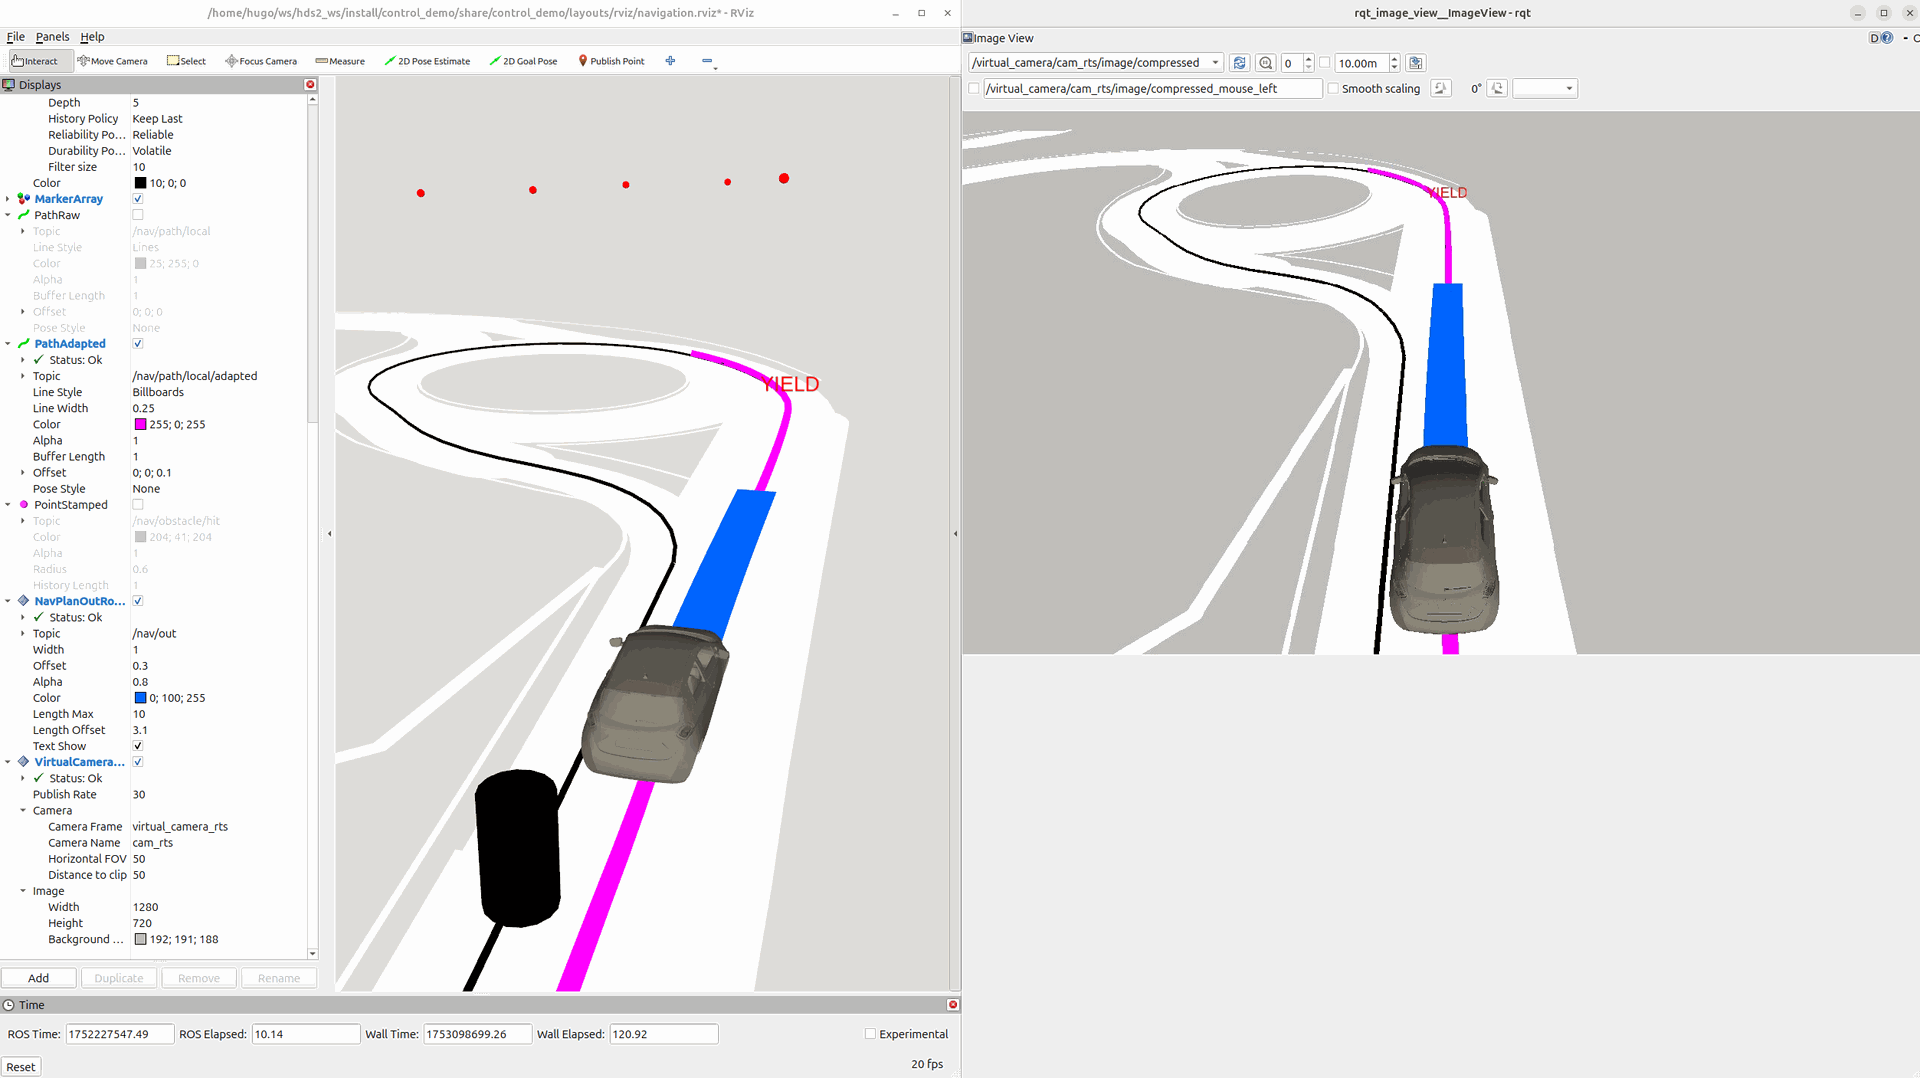
RViz2 - Virtual Camera
RViz2 plugin to publish virtual camera views as ROS 2 image topics for simulation, testing, and visualization.
2024
 20 Dec 2024
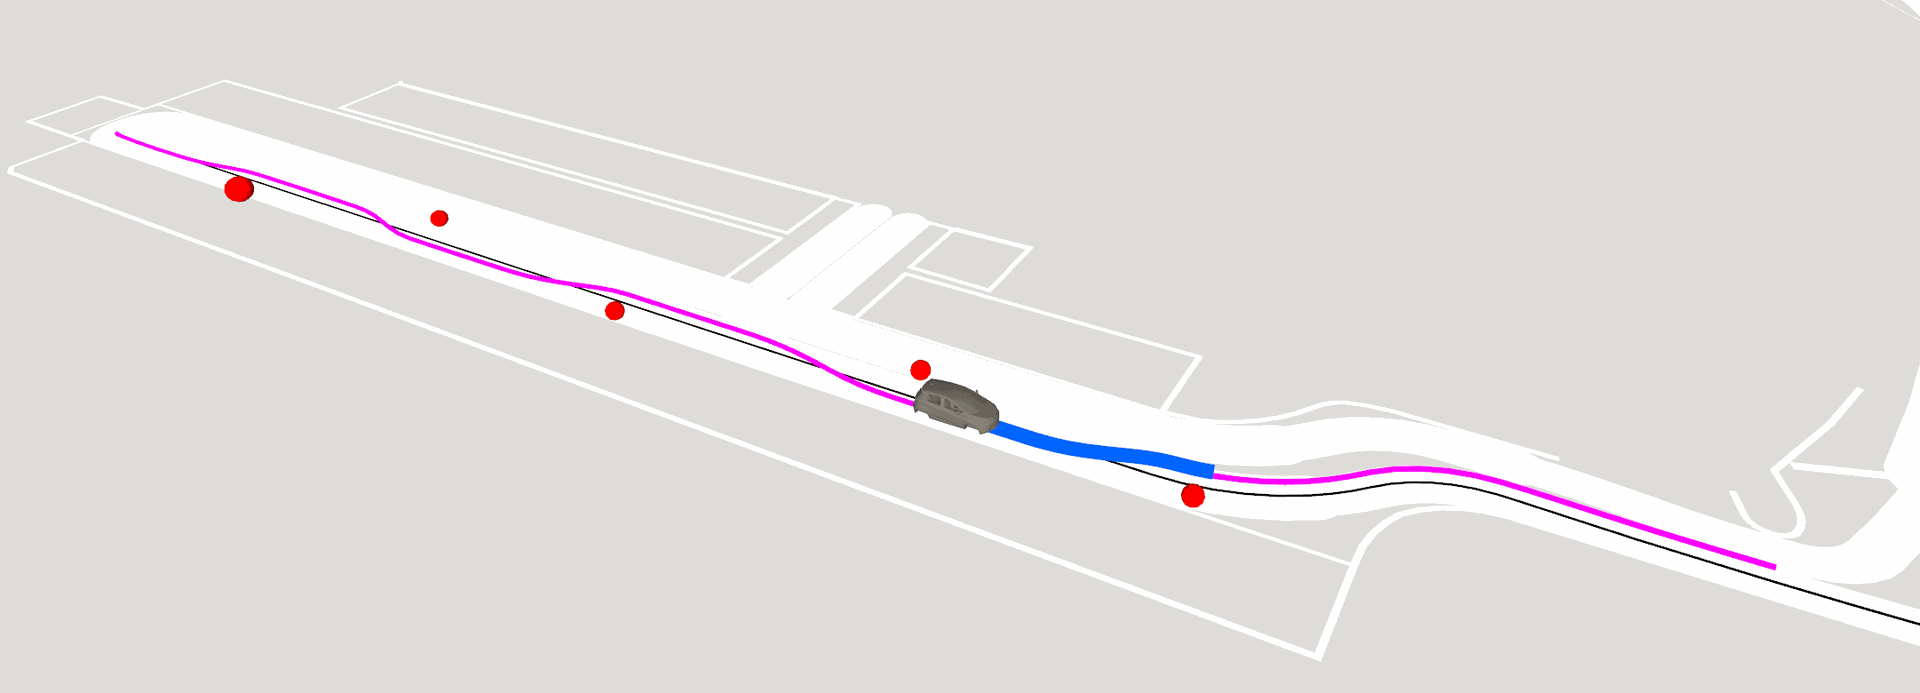
Autonomous Vehicle: Control
Lateral and longitudinal control applied to a real autonomous vehicle, integrated with a navigation layer.
 10 Dec 2024
Autonomous Vehicle: Planning
Local planning applied to real autonomous vehicles, combining global route planning, local path adjustment, and dynamic control profile.
 11 Oct 2024
2023
 10 Dec 2023
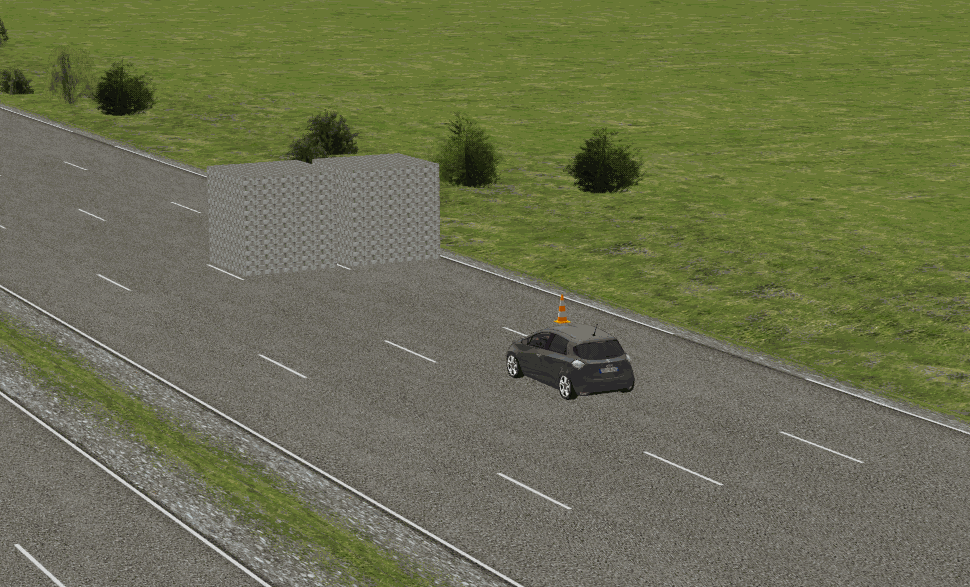
Driving Intention Quantification Formula
Define a quantification formulation measuring the quality of driving intentions, used to compare and rank them.
 01 Feb 2023
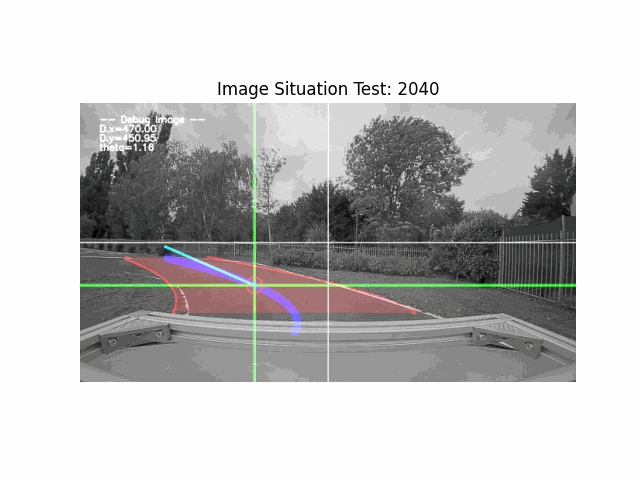
Visual Control Applied To Autonomous Vehicle
Control a vehicle using only camera images by linking lane features to vehicle speed and orientation.
2022
 10 Nov 2022
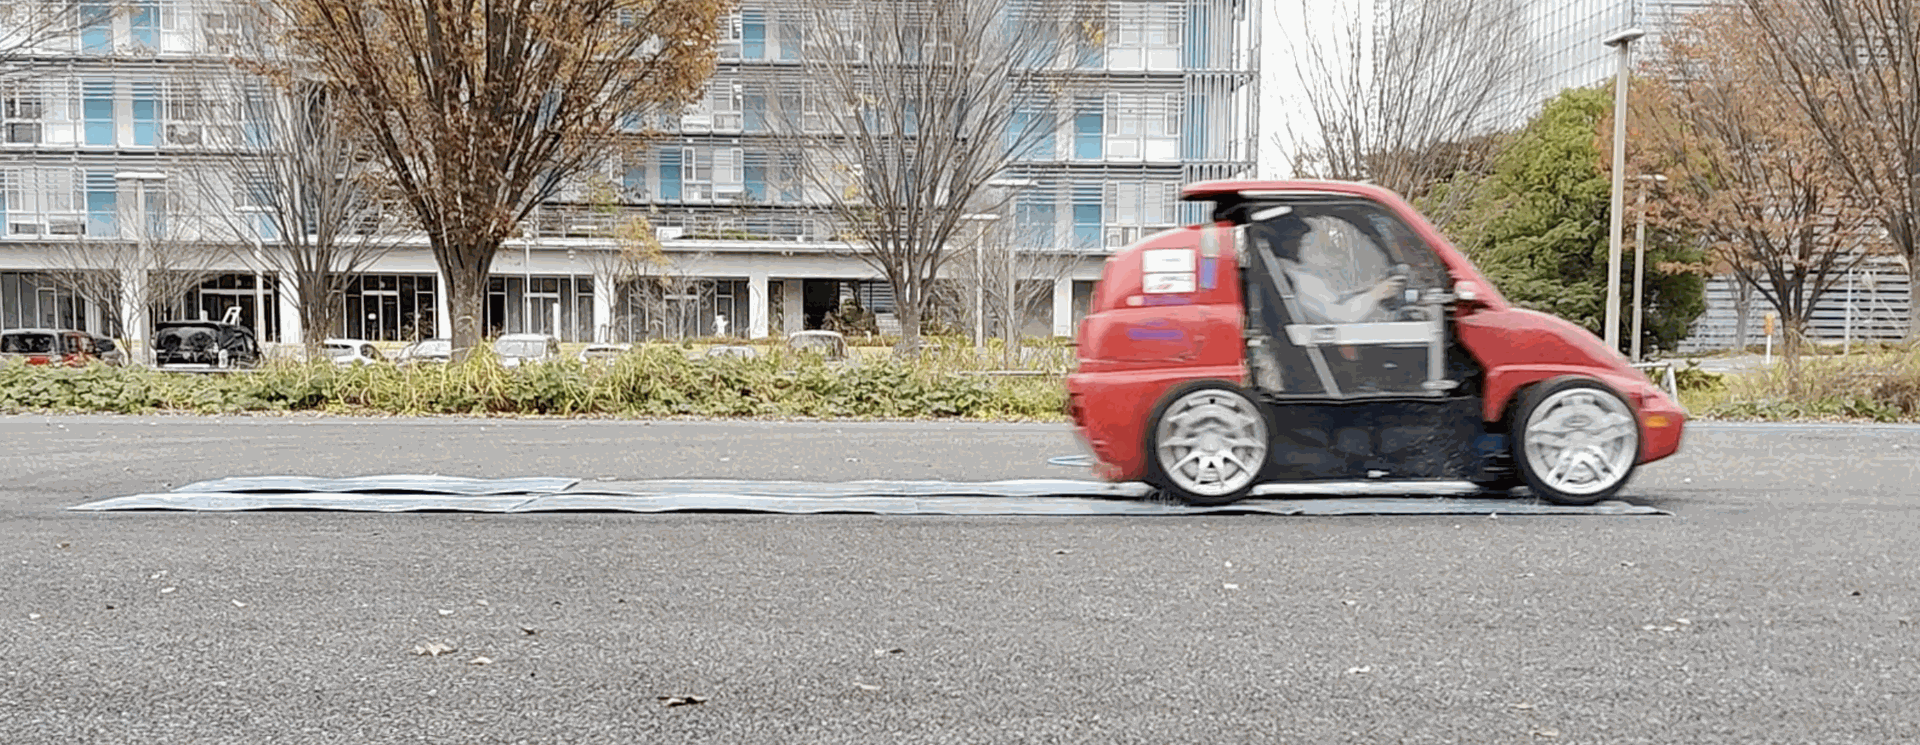
Friction Camera Detection
Road friction estimation based on surface segmentation using a camera and projection into a global grid.
 10 Aug 2022
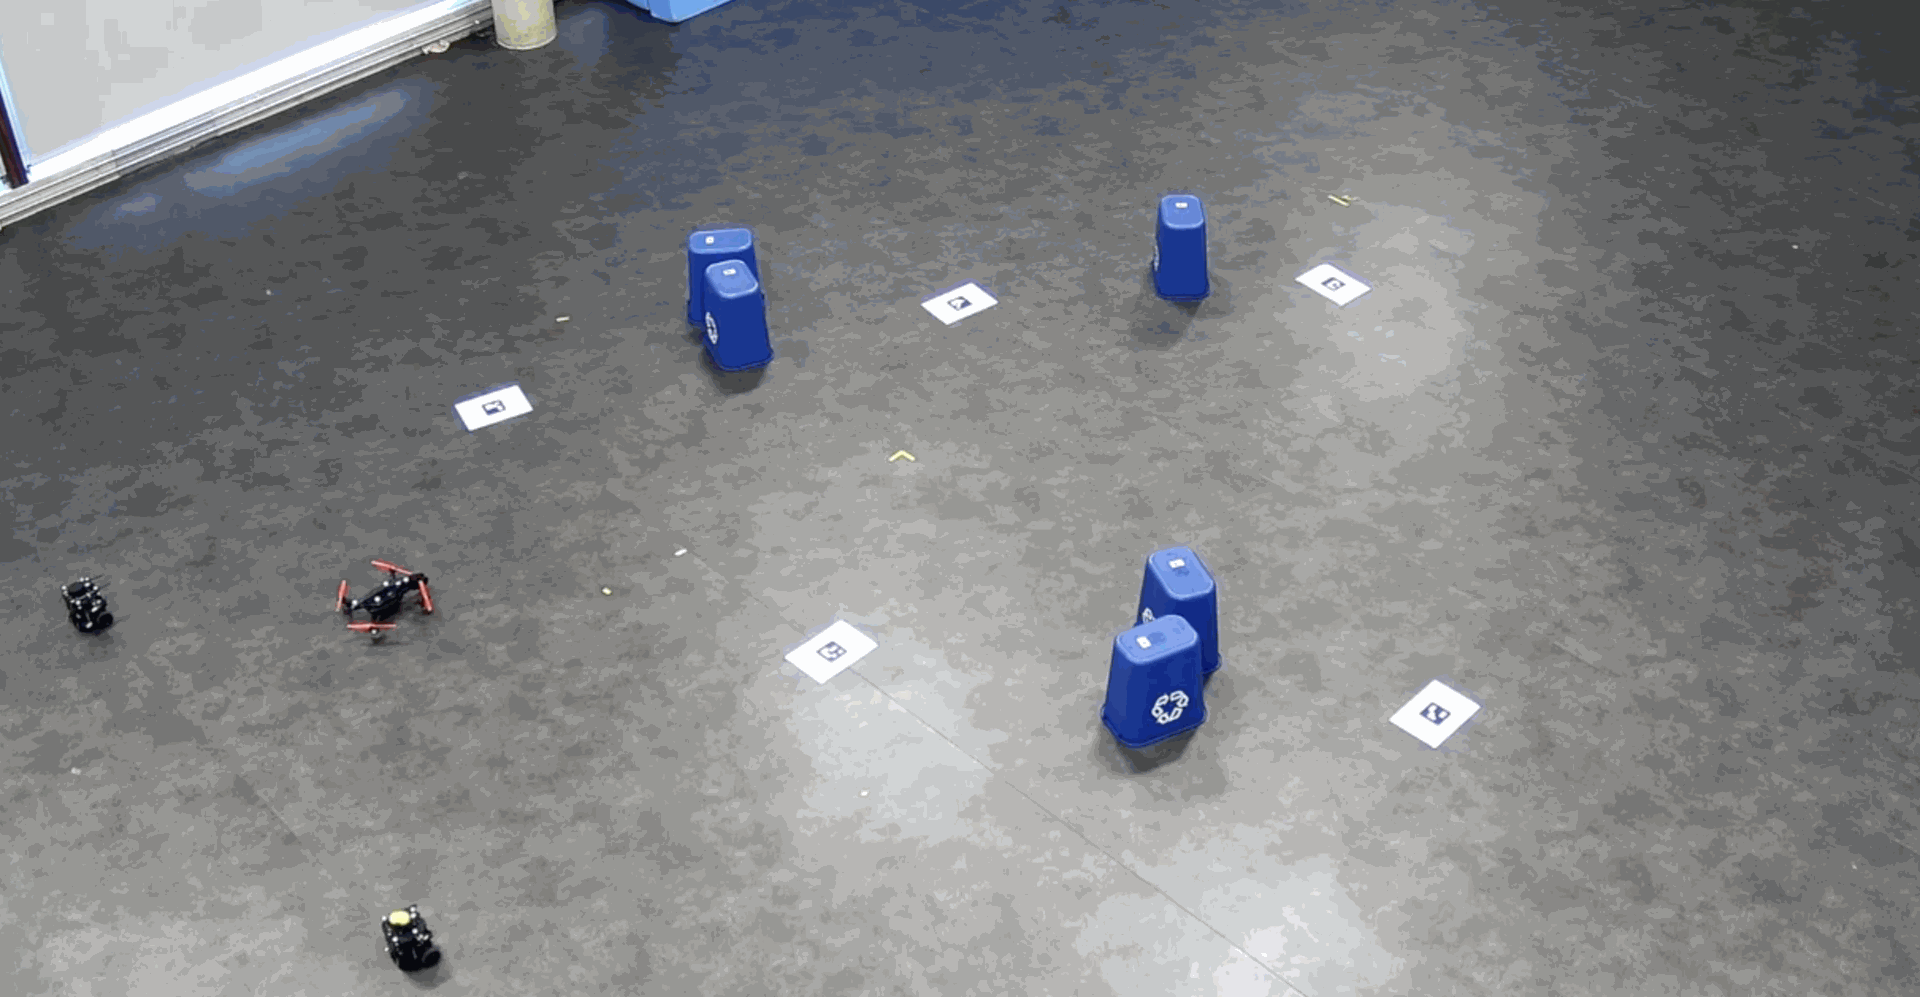
Multi-Robot ROS Architecture for UGV/UAV Coordination
Modular ROS architecture enabling coordinated task execution between drones and ground robots using TCP.
 10 Mar 2022
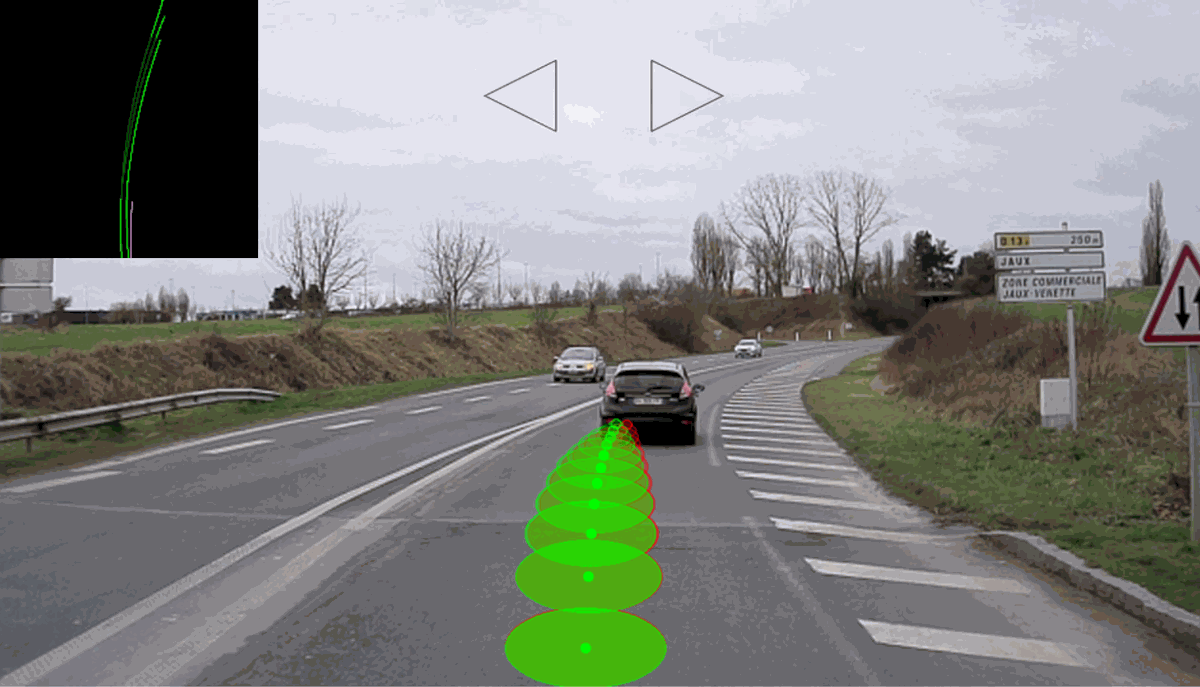
Human Driving Behavior Prediction
Prediction of short-term human driving behavior using previous vehicle states, based on a deep learning model integrating multiple sensors.
 10 Jan 2022
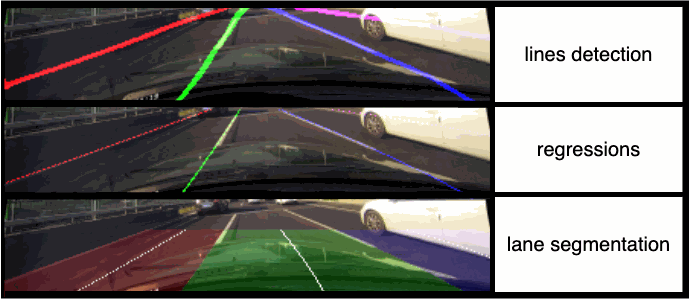
Lane Detection
Lane detection from camera images using a deep-learning autoencoder.
2021
 10 Dec 2021
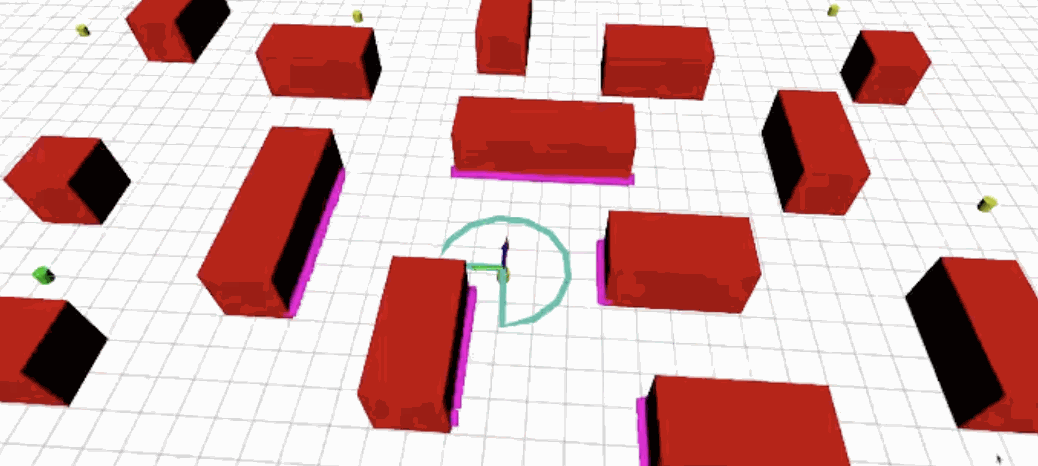
Optimization of the Dynamic Window Approach (DWA)
Gradient descent formulation applied to the Dynamic Window Approach for improved convergence and trajectory quality.
2020
 10 Dec 2020
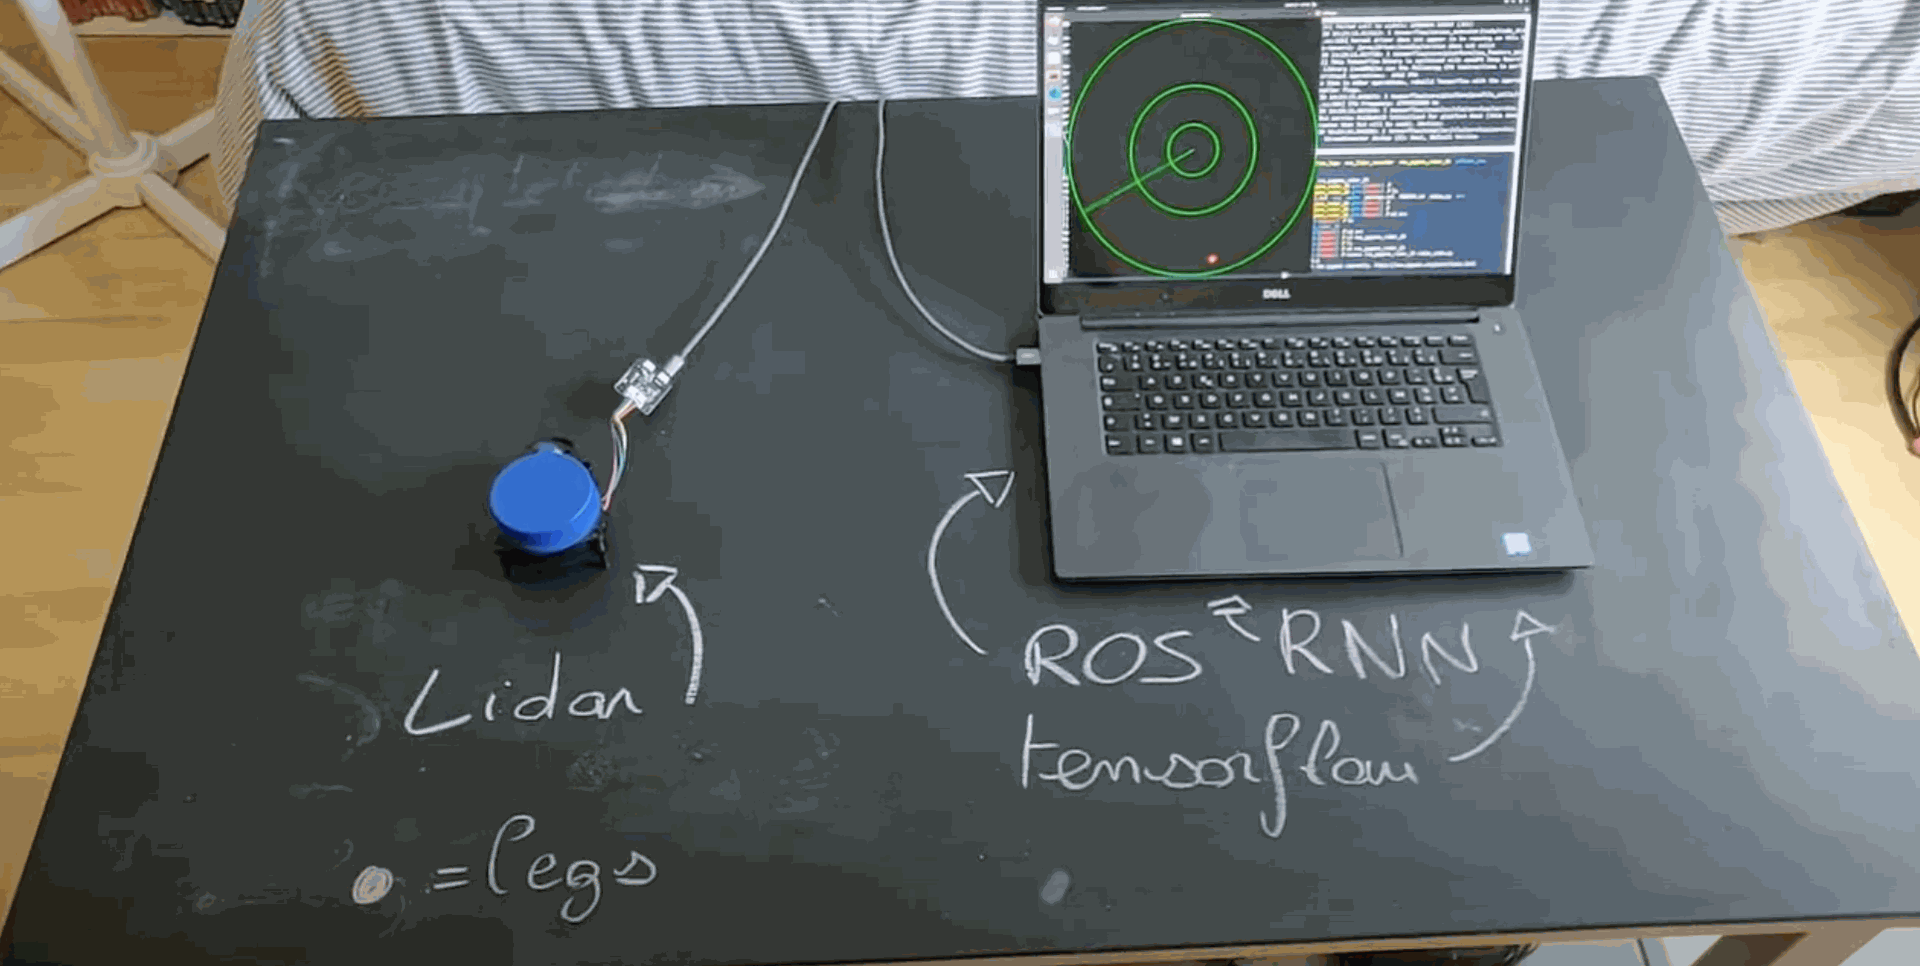
Leg Detection Using a 2D LiDAR
Leg detection using an LSTM classifier on spatial LiDAR sequences.
 07 Sep 2020
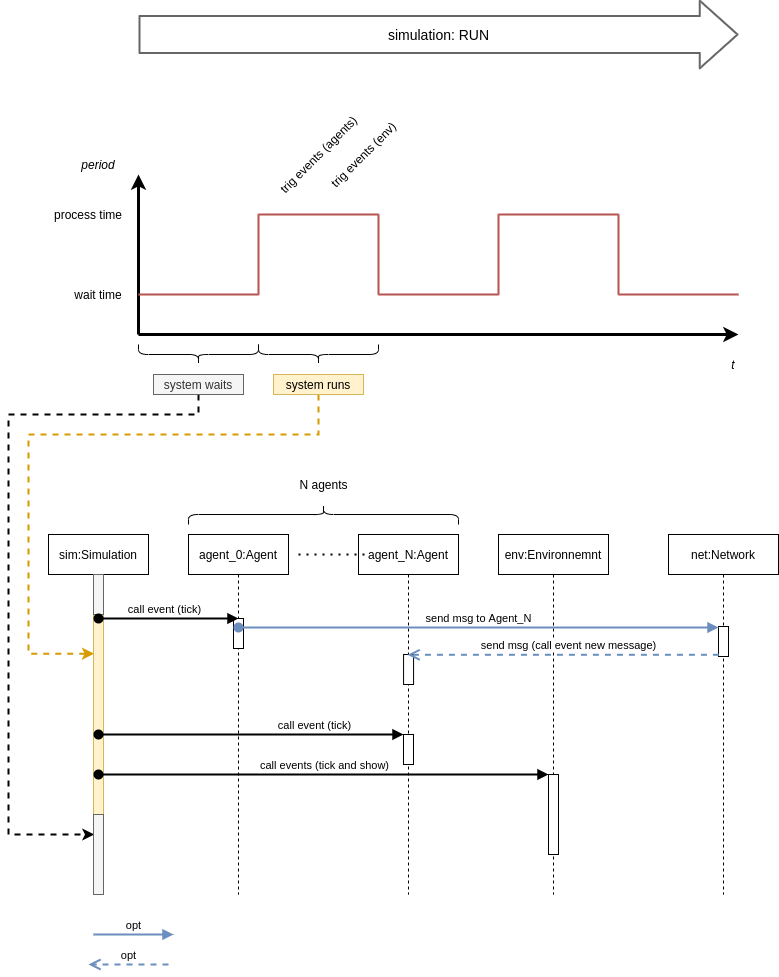
A Lightweight Multi-Agent System Library
A lightweight Python library to build and simulate multi-agent systems with agents, environments, and message-passing networks.
 15 Jun 2020
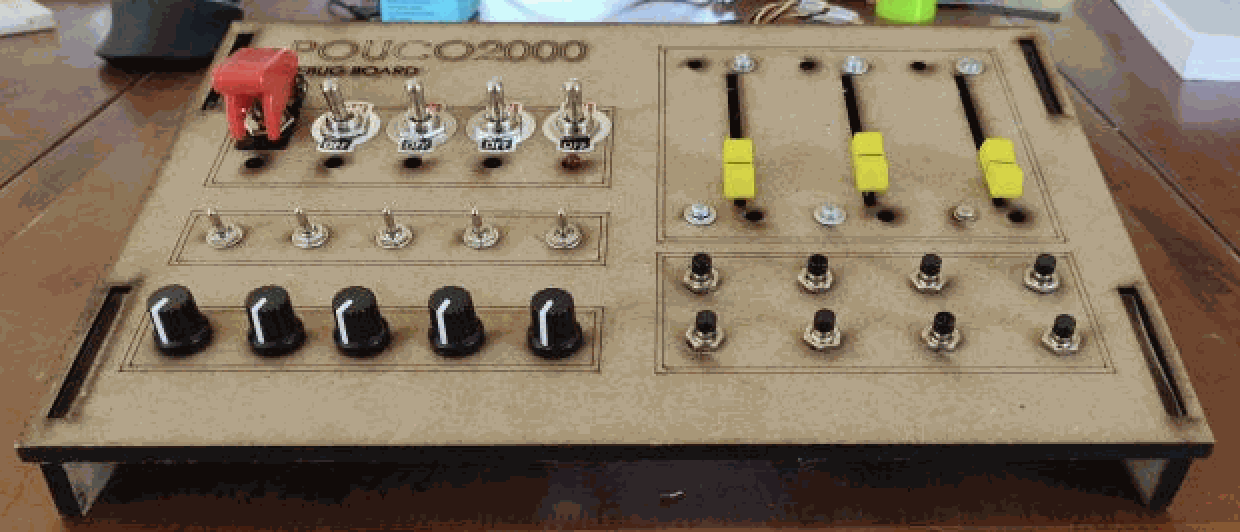
Pouco2000 - Customizable Physical Interface for ROS Robots
Modular physical control panel for interacting with ROS-based robots, with Arduino and ROS integration.
2019
 01 Feb 2019
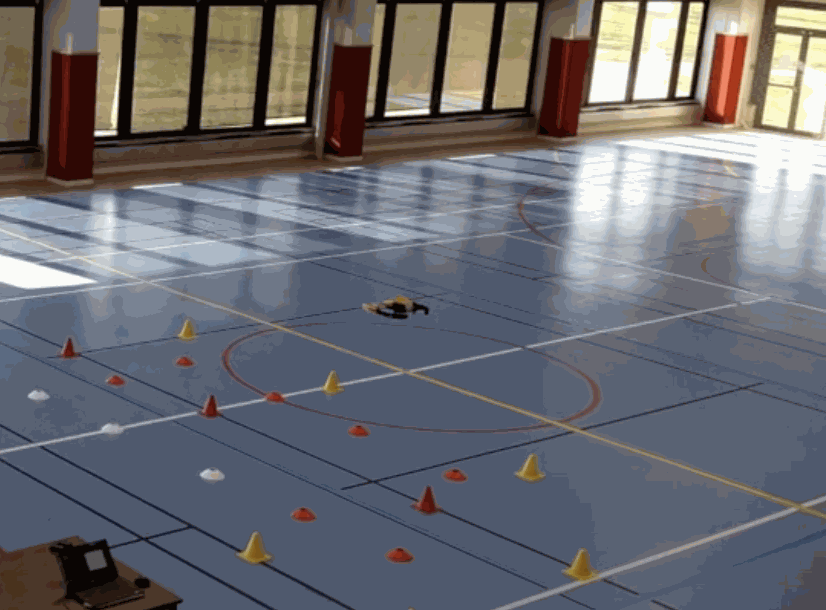
Drone Control with ROS
Control of a Parrot drone using ROS.
2017
 07 Aug 2017
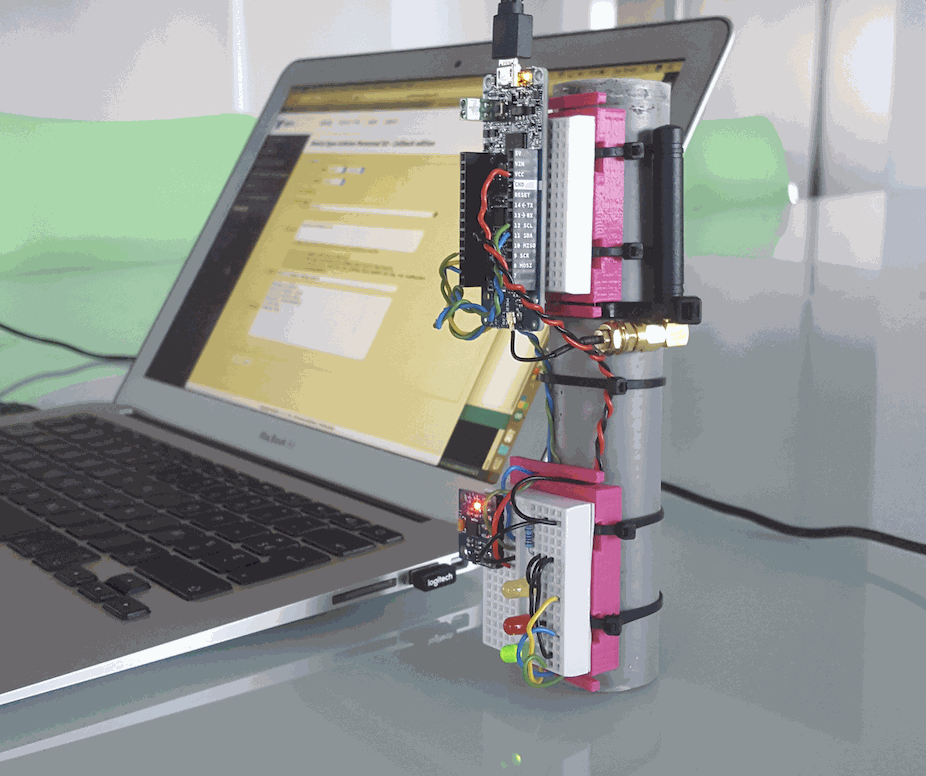
Lovo Anti-theft Bicycle Connected
Connected anti-theft bicycle system using Arduino, IMU, Sigfox, and Firebase to detect motion and notify users.